The EA09's firmware implements four PID controllers for Robotino's three drive motors and the optional fourth motor. The PID controller equation is:
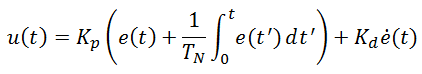
The PID controller's parameters are:
Kp
Ki = 1/Tn
Kd
The firmware implements the controller in integer arithmetic. The values kp , ki and ki are integer values in the range [0;255]. From these values we calculate Kp , Ki and Kd
Kp= kp / 2
Ki= ki / 1024
Kd= kd / 2
From the Telnet user interface you are setting kp , ki and kd.
The maximum Kp is 255 / 2 = 127,5.
The maximum Ki is 255 / 1024 =0,249. The maximum reset time Tnmaxis 1024ms because Ki=0 disables the I-control part. Tnmax is a theoretical value. The integral over the deviations from the speed set-point e(t) is computed over the previous 64ms only.
The maximum Kd is 255 / 2 = 127,5
Default values programmed into the firmware are:
kp = 25
ki = 25
kd = 25