Represents a digital output device.
More...
#include <ElectricalGripper.h>
|
| enum | { IsMoving,
IsOpen,
IsClosed
} |
| |
|
|
class | ElectricalGripperImpl |
| |
Represents a digital output device.
| void rec::robotino::api2::ElectricalGripper::close |
( |
| ) |
|
Close the electrical gripper.
- Exceptions
-
| bool rec::robotino::api2::ElectricalGripper::isClosed |
( |
| ) |
const |
| bool rec::robotino::api2::ElectricalGripper::isOpened |
( |
| ) |
const |
| void rec::robotino::api2::ElectricalGripper::open |
( |
| ) |
|
Open the electrical gripper.
- Exceptions
-
| void rec::robotino::api2::ElectricalGripper::setComId |
( |
const ComId & |
id | ) |
|
Sets the associated communication object.
- Parameters
-
| id | The id of the associated communication object. |
- Exceptions
-
| virtual void rec::robotino::api2::ElectricalGripper::stateChangedEvent |
( |
int |
state | ) |
|
|
virtual |
Called when the grippers state changes
- Parameters
-
| state | ElectricalGripper::IsOpen if the gripper is opened. ElectricalGripper::IsClosed if the gripper is closed. ElectricalGripper::IsMoving is the gripper is moving, i.e. between opened and closed. |
- See also
- Com::processEvents
The documentation for this class was generated from the following file:
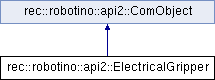
 Public Member Functions inherited from rec::robotino::api2::ComObject